 Xem Studiomeasured geometry
Library › Mechanisms › Couplings & joints ·
Universal (Hooke / Cardan) joint, drawn at 30°
Why does a universal joint not turn at constant speed? · Hardware · basis: Xem Studio design following Brown No. 50 (1868)
Also called: universal joint, cardan joint, hooke joint, u joint speed, junta cardán, Kardangelenk, junta cardan
Exact dimensions. True size, with no tolerance added.
- sizes
- 4 in table
Notes
- Resize: multiply every length by one factor k and the motion stays identical: angles, ratios, timing and the formulas below do not change, because a mechanism's motion depends only on the ratios of its lengths. Here, scales with k: yokes, cross; stays the same: speed swing at 30°; step to the nearest standard size (and redraw the hole or pocket it fits): shaft angle β (drawn).
- Resize: fit clearances stay in mm (a slide fit is the same gap at any size); keep every printed wall and pin at least two nozzle widths; mass grows with k³ but part strength only with k², so at k = 2 parts are about 8× heavier and 4× stronger: check pins and thin links when scaling up.
- Two yokes at 90° on a cross: shafts at an angle β turn together, but the output speed swings: ω₂/ω₁ = cos β / (1 − sin²β·cos²θ), between cos β and 1/cos β twice per turn.
- At the drawn β = 30° the output runs between 0.866 and 1.155 × input speed. Two joints in phase with equal angles (a double Cardan, or a drive shaft with both inner yokes aligned) cancel the swing.
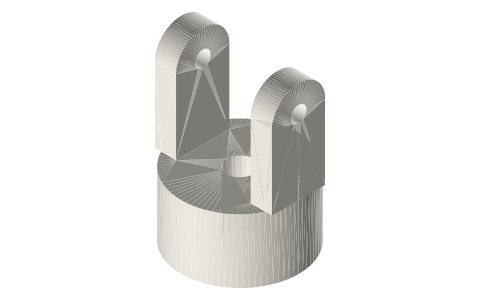
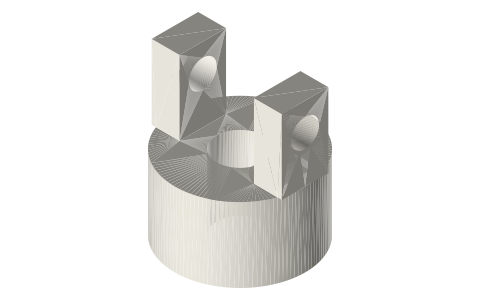
- Drawn with the Ø22 Cardan yokes (forks long enough for 30°), the 14 mm cross, a Ø3 × 20 through pin and two Ø3 × 10 short pins, on Ø5 shafts. The smaller Ø14 printable joint (universal-joint-5mm) works up to about 18°.
- Brown shows two forms (Nos. 50 and 51). Parts (each has its own page): cardan-yoke-22-5mm, cardan-spider-14, dowel-pins-metric.
Universal (Hooke / Cardan) joint, drawn at 30° size chart
| parameter | value |
|---|---|
| shaft angle β (drawn) | 30° |
| speed swing at 30° | 0.866 – 1.155 |
| yokes | Ø22, Ø5 bore |
| cross | 14 × 14, 7 mm arms |
Where the files are
Other publishers' files are linked, not hosted. "verify" = check the license at the link before commercial use.
| Henry T. Brown (1868, public domain) | Five Hundred and Seven Mechanical Movements — scan on archive.org | web | Publisher's page; dimensions are facts |
| 507movements.com | Brown's movement No. 50: figure, his text and an animation | web | Publisher's page; dimensions are facts |
Free files
★ Free files 1 parts. Xem Studio design: free to use, print and sell things from; not to be republished as files. Xem Studio Design License. index.json
Use this part in your AI. Your AI gets the exact sizes and files straight from Xem and can design a mount, case or adapter around it. Direct downloads here are limited to one file every 10 minutes; through your AI they are unlimited.
Connect Xem to your AI (free, no account, about a minute)
https://xemstudio.com/mcp- Claude: Add to Claude
- ChatGPT (Plus or higher): open Connectors → Advanced → turn on Developer mode → Create → paste the address, no authentication → Create.
- Cursor: install with one click. VS Code: install with one click.
| universal-joint-mechanism-assembly | Assembled mechanism, all parts placed at one pose (STEP keeps each part separate) | STEP · STL |
https://xemstudio.com/mcp to Claude, ChatGPT, Cursor or any MCP client (free, no account, one minute) and it can look up exact sizes, mating fits and free STEP/STL from every chat.Plain text: sheet.txt · JSON: /api/geometry?object=universal-joint-mechanism

Fits with


Questions
Why does a universal joint not turn at constant speed?
The cross tilts as it turns: output speed swings between cos β and 1/cos β of input, twice per turn.
How do you cancel the speed swing?
Use two joints at equal angles with the yokes on the middle shaft in line (in phase).